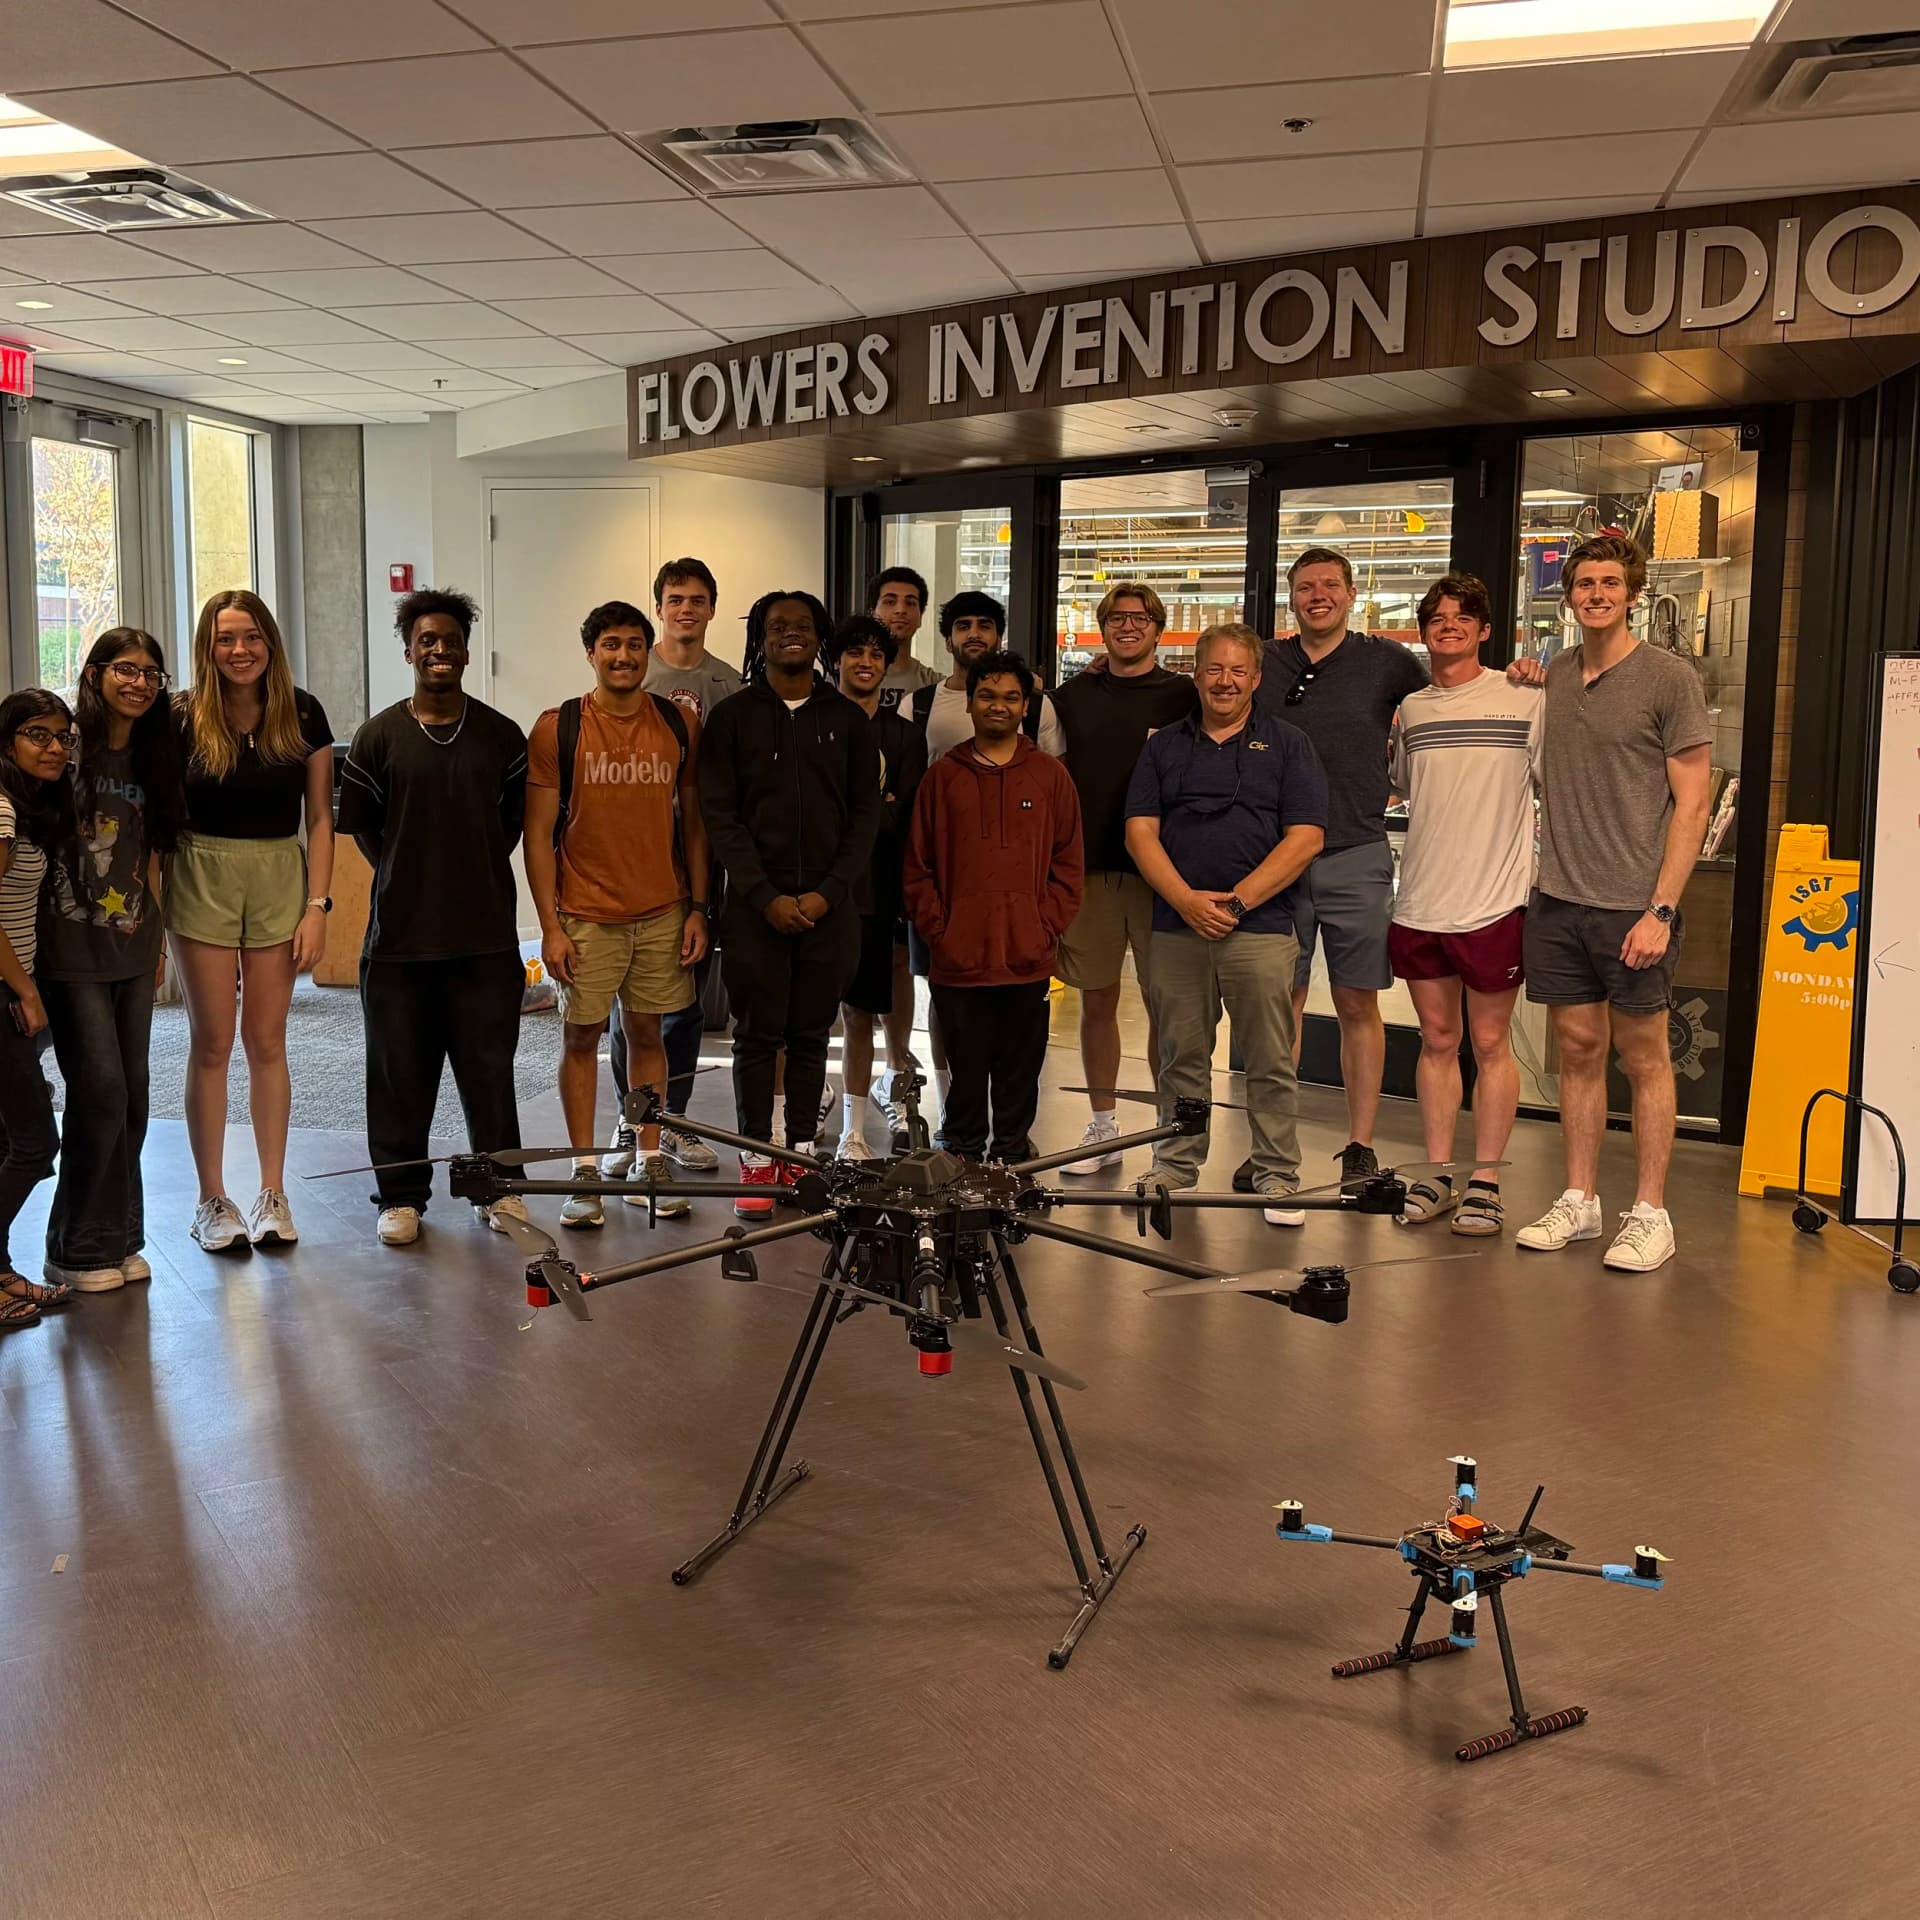
RRT-based flight path optimization in C++ for scout drones searching a 1,000 km² area under a 10-minute fire detection deadline, plus a neural network pipeline classifying high-risk vs. low-risk fires from thermal and smoke-particle data. Built for the XPRIZE Wildfire competition (team of 15).
C++PyTorchQGroundControlOpenGCS